Planetary Gearbox
A compact planetary gearbox designed to reduce speed and increase torque for small motor-driven applications.
Overview
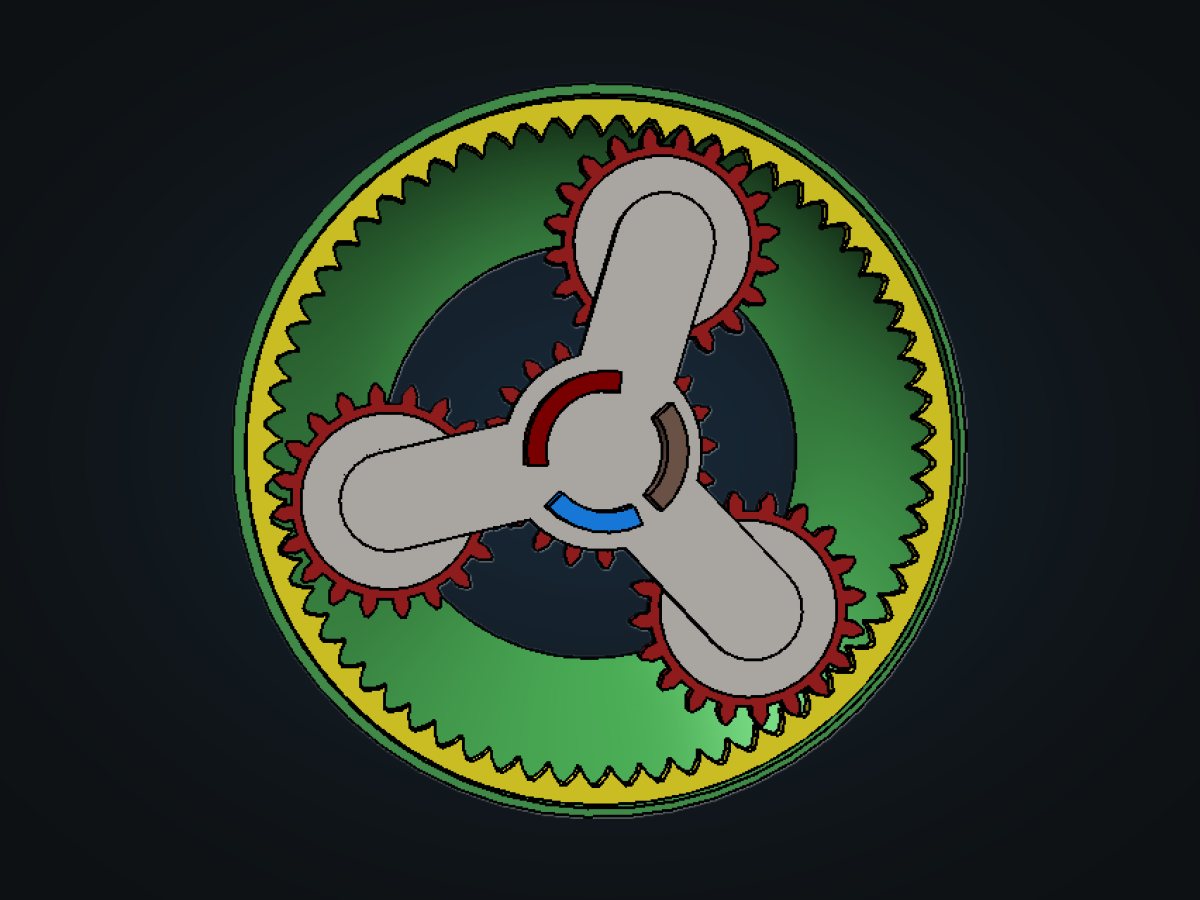
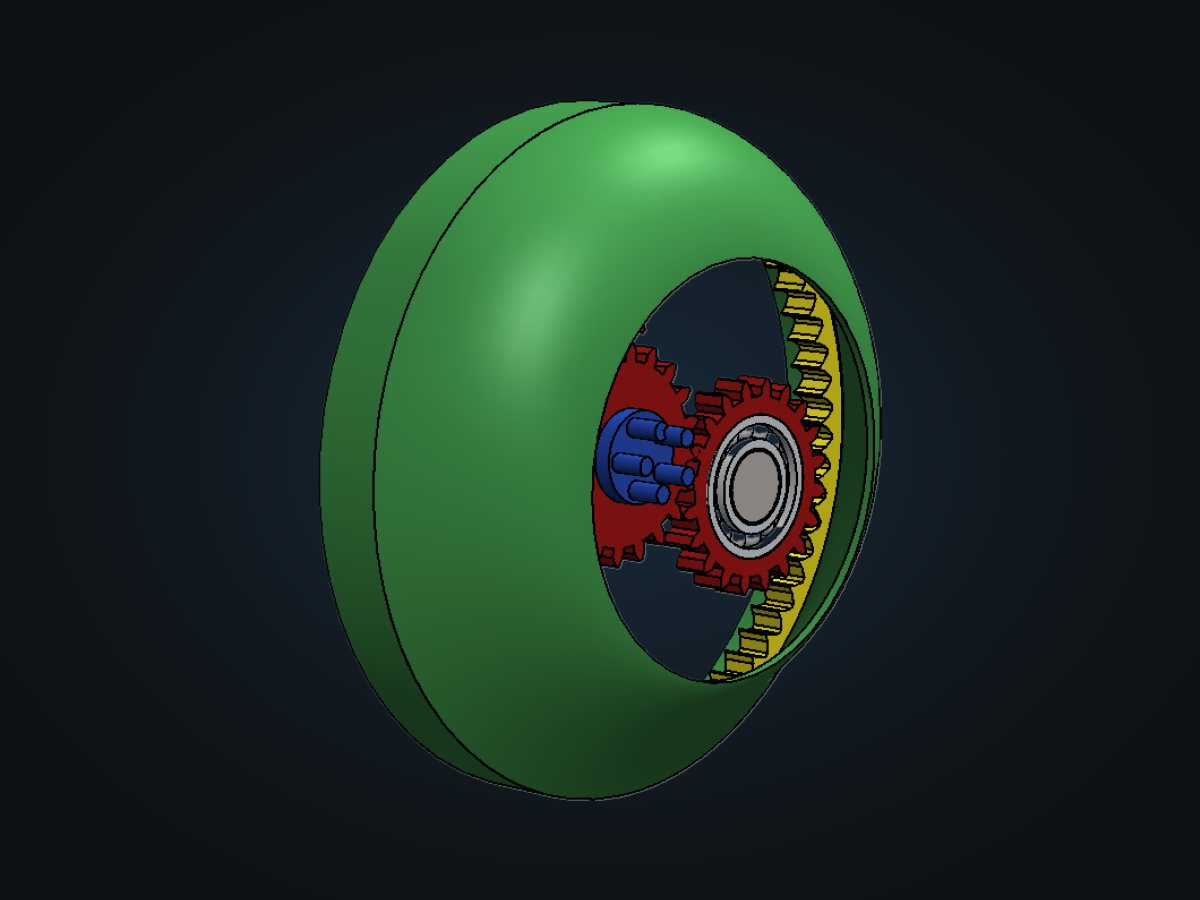
A compact planetary gear train for torque multiplication and speed reduction in small motor-driven mechanisms, modelled and assembled in SolidWorks.
Small motors spin fast and push weakly, and most robot joints need the opposite. A planetary layout shares the load across several gears at once, so a small housing can carry more torque.
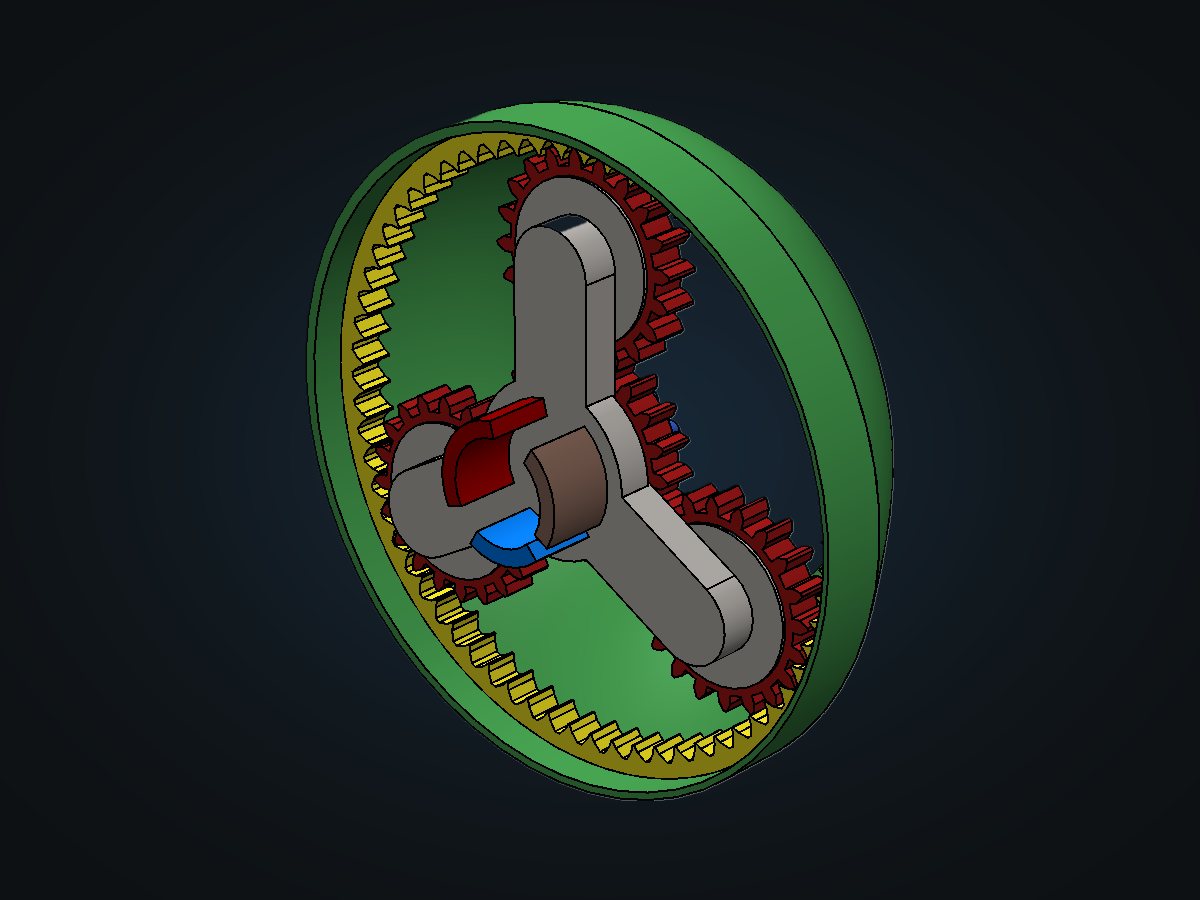
- Sun, planet and ring layout
- Load shared across the planets
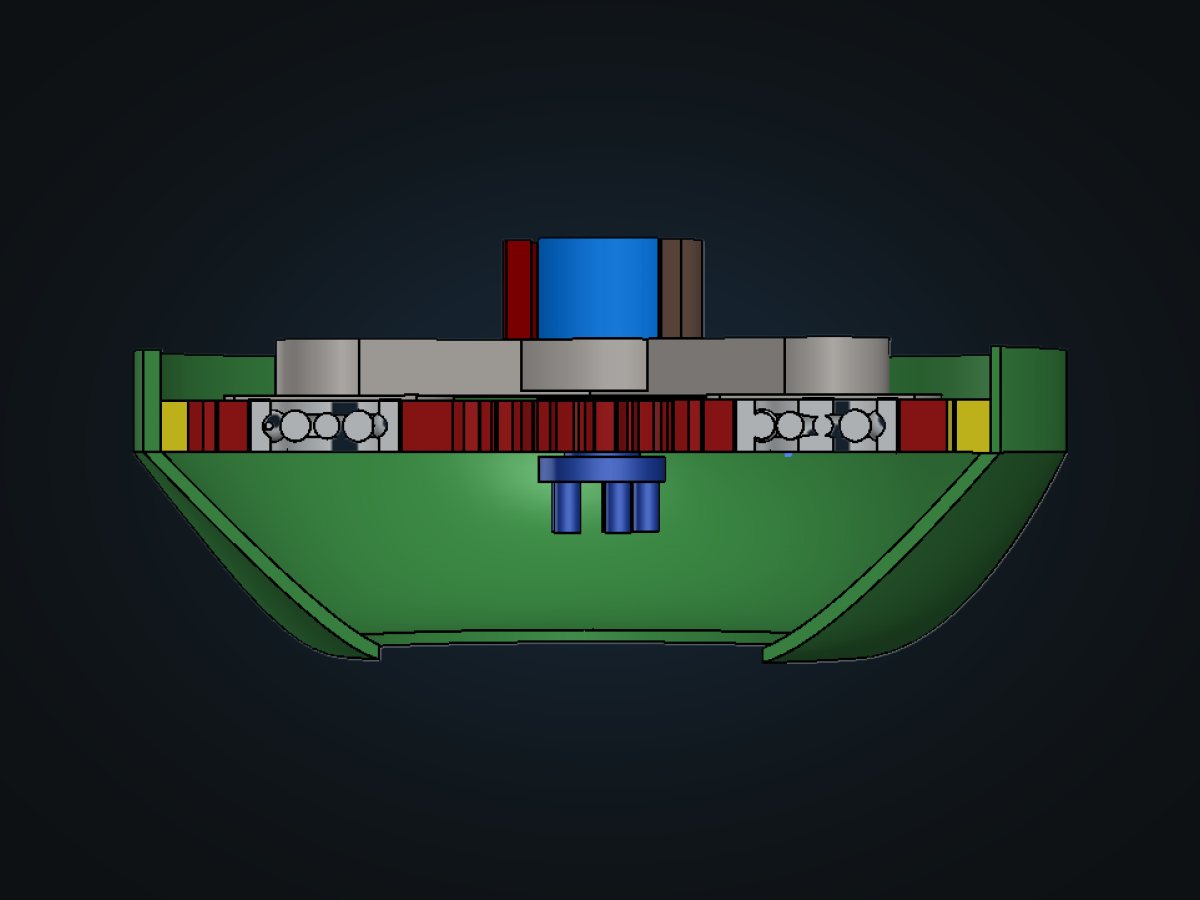
- Compact, concentric housing
- Motor input shaft
How it works
The planets have to mesh with the sun and the ring at the same time and sit evenly around the sun, which is what decides the tooth counts.
A motion study runs the assembly so the mesh can be checked in SolidWorks.
Challenges
A design exercise rather than a build. The main constraint was getting the planets to mesh with both the sun and the ring while spacing evenly, since that fixes the tooth counts before anything else can be decided.
Gallery
Build Details
| Software | SolidWorks |
|---|---|
| Layout | Sun, planets, ring |
| Output | Carrier |
| Checked with | Motion study |