6-Axis Robotic Arm
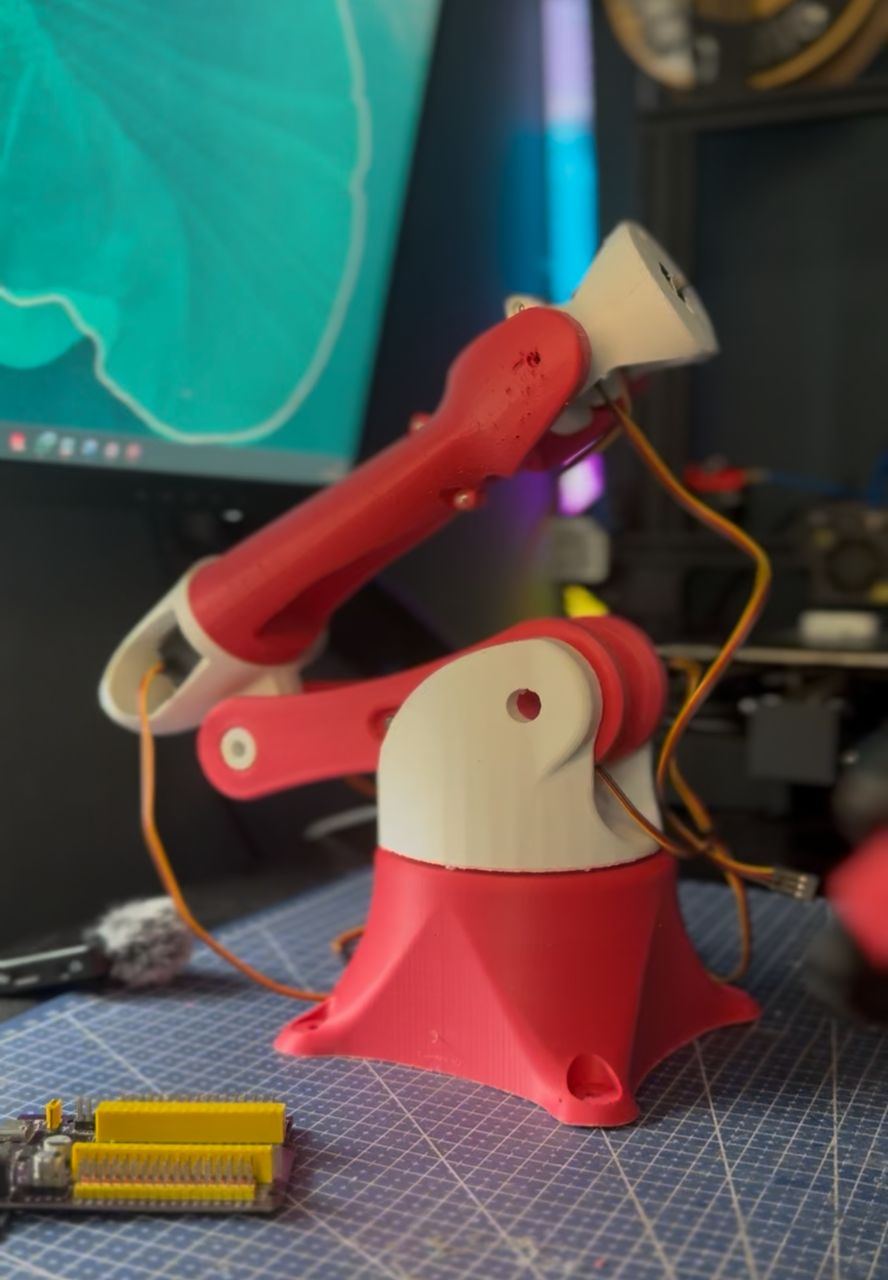
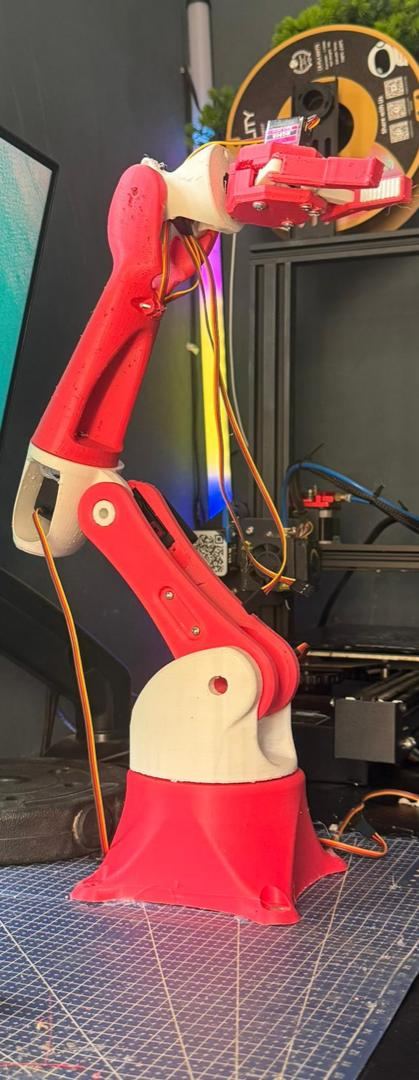
A six-axis 3D-printed robotic arm based on an existing design. I used the build to investigate why the servos were failing and understand the mechanical and load-related problems in the system.
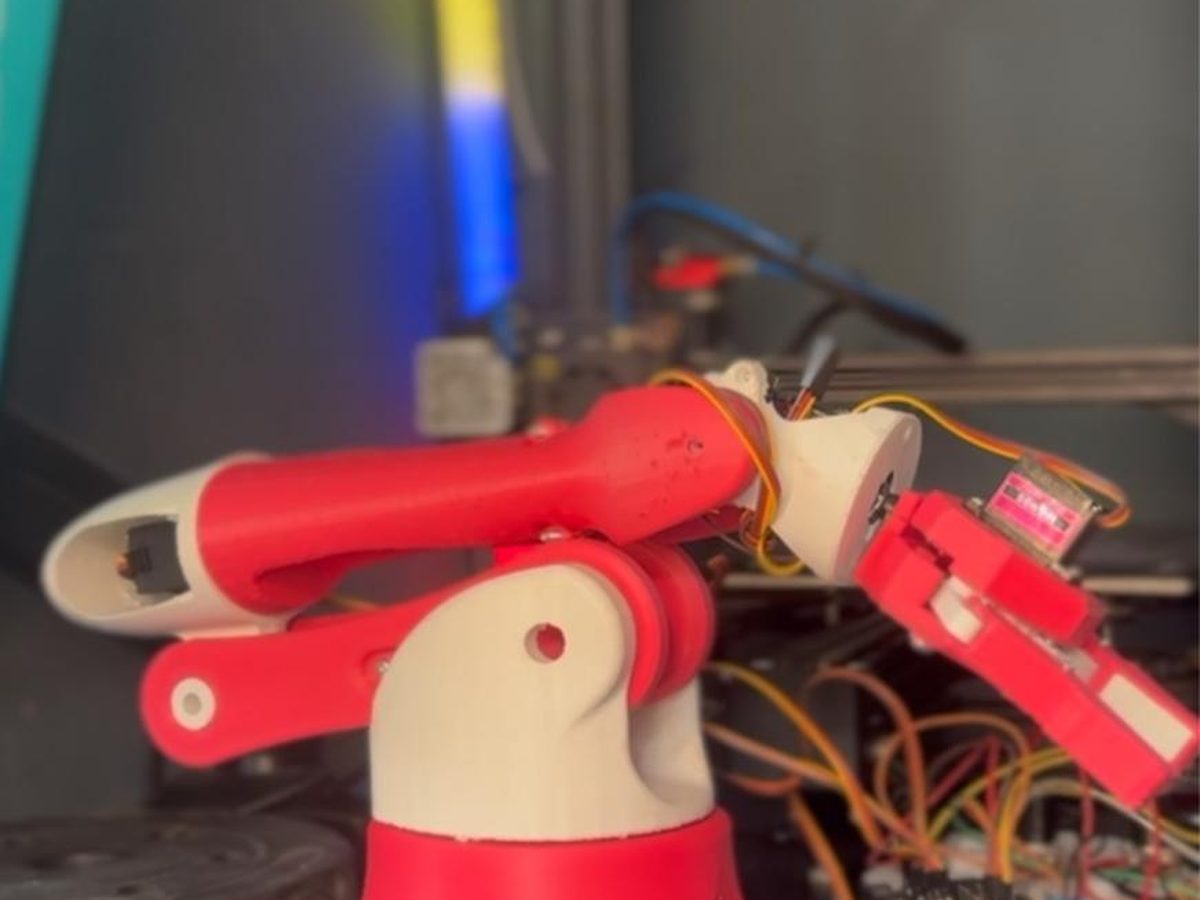
Watch it working
Overview
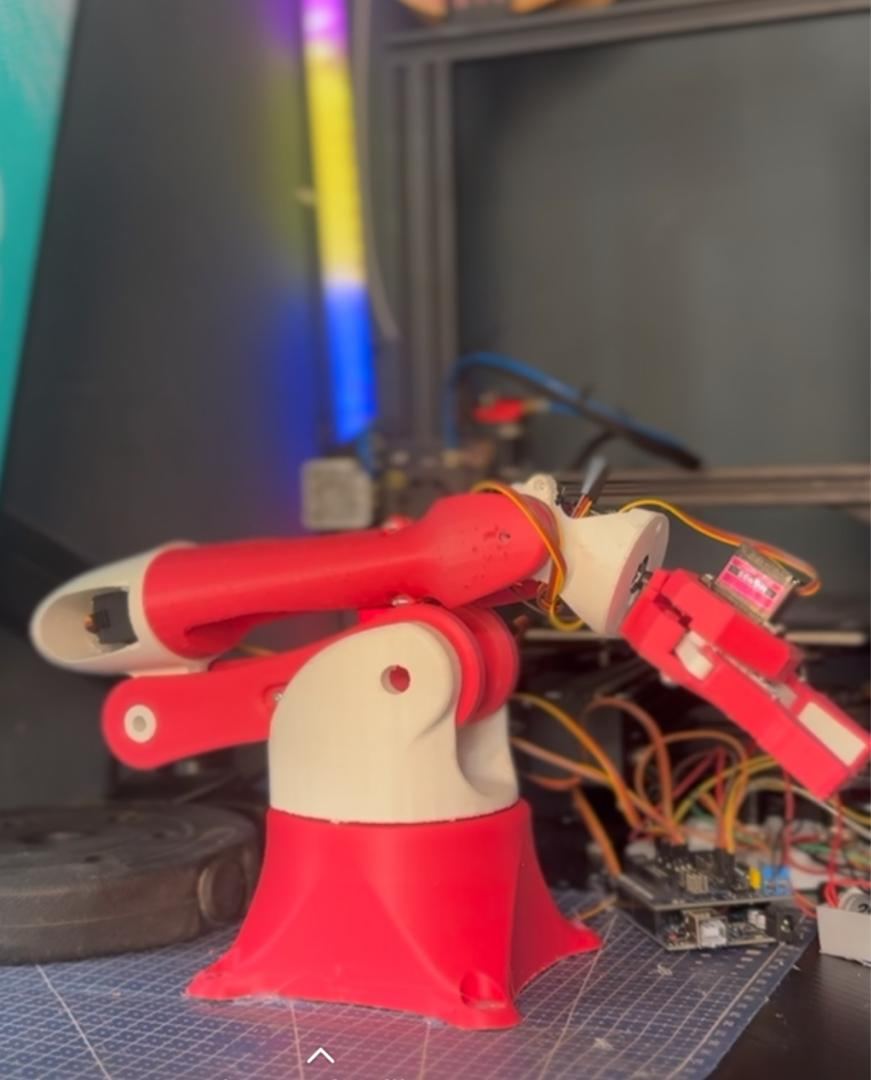
A six-axis 3D printed arm with a rotating base, shoulder, elbow, wrist rotation and a working gripper. I bought the STL files, printed and assembled it, and wrote my own control program for an Arduino Uno.
I wanted an arm to work with without spending weeks modelling one, so I used an existing design. The design is not mine. The build, the wiring, the control, and working out why it failed are.
- Six axes, from the base to the gripper
- One potentiometer per joint for exact positioning
- Arduino Uno control, my own program
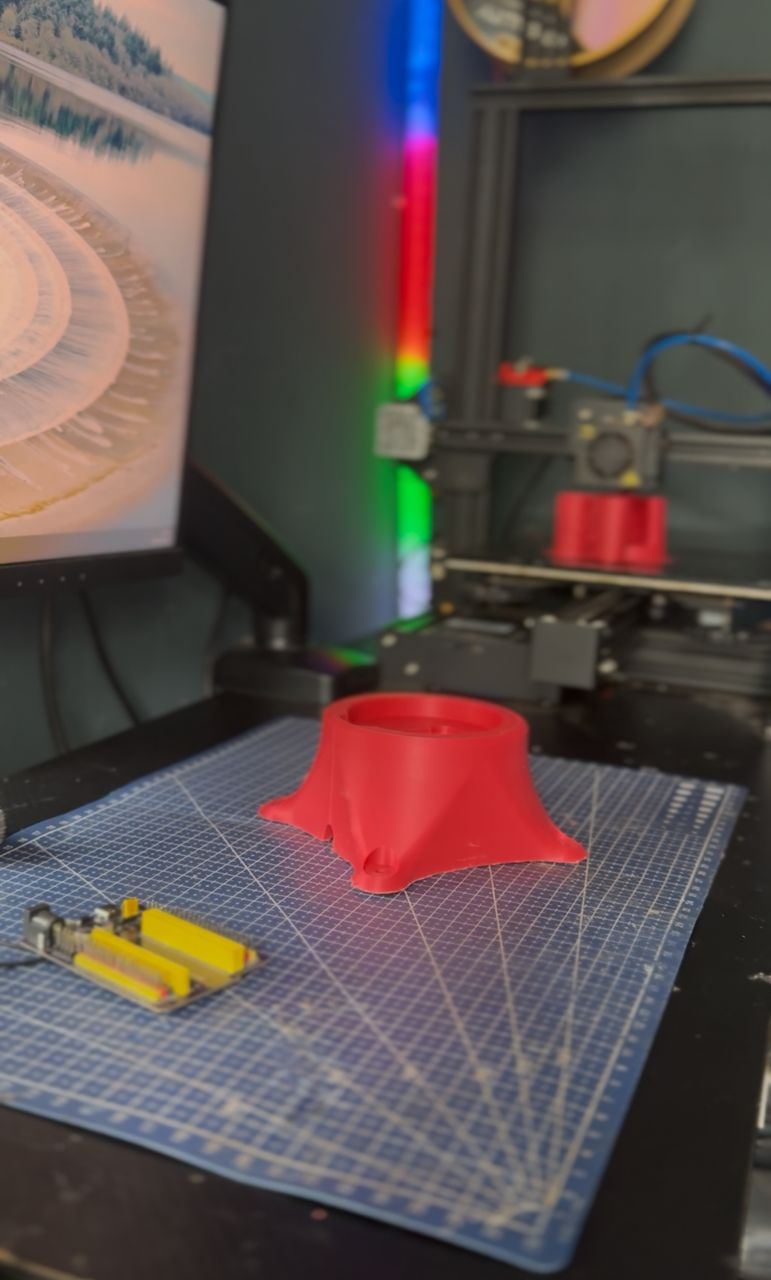
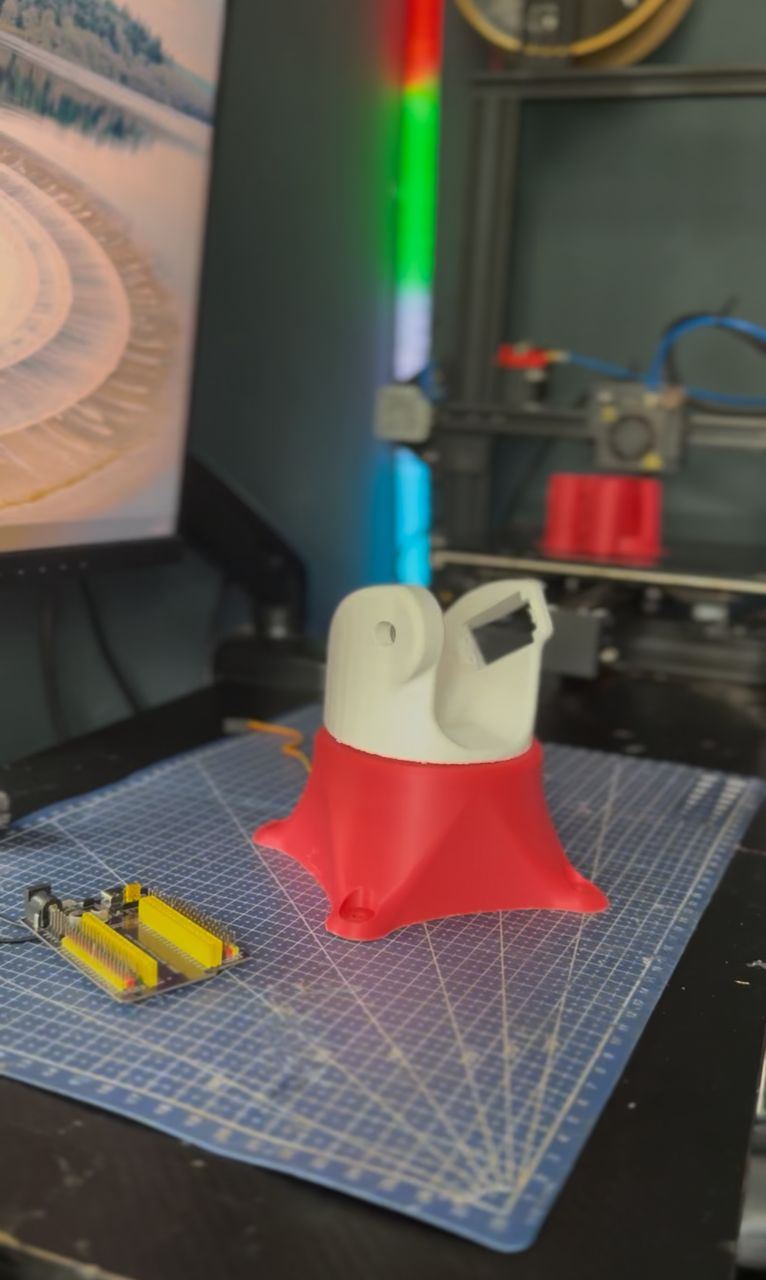
- Printed in matte PLA
How it works
Instead of inverse kinematics, each joint has its own potentiometer. Turning a dial sets that joint to an exact angle. It is manual control, but it is enough to load every axis and see how the arm behaves.
Under test, the shoulder and elbow servos failed repeatedly. Only the lighter joints moved reliably.
Challenges
The cause was weight, not the servos themselves. The links are heavy and the design places that weight far from the shoulder, so the torque needed to hold the arm up is more than the servos can supply. The design is also more complex than the job needs, which adds material and weight. I stopped there rather than keep replacing servos.
What I would do next
A rebuild from scratch: lighter links, less infill, and the torque at each joint worked out before anything is printed.
Gallery
Build Details
| Axes | 6 |
|---|---|
| Controller | Arduino Uno |
| Servos | MG996R |
| Control | One potentiometer per joint |
| Material | Matte PLA |
| Design | Purchased STL files |